A Survey: Learning Embodied Intelligence from Physical Simulators and World Models
arXiv preprint arXiv:2507.00917 · 2025
Abstract
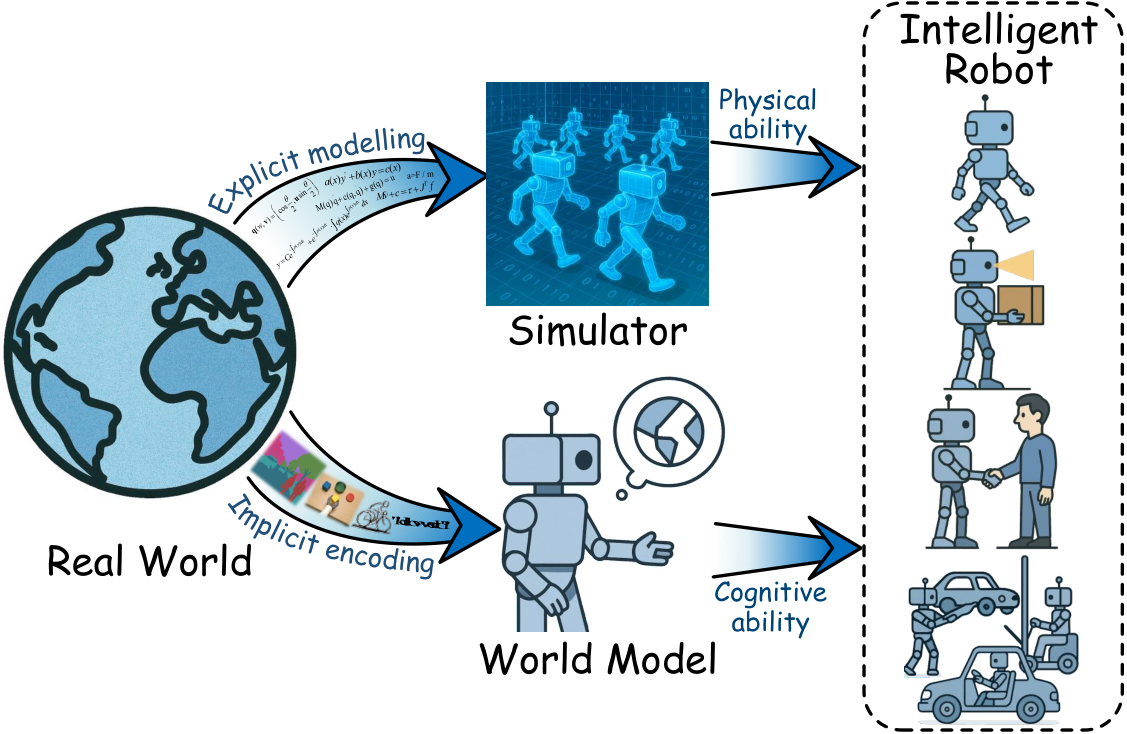
A review of physical simulators and world models for embodied intelligence, covering their complementary uses in robot learning, planning, and transfer to real environments. The accompanying repository collects related literature and open-source projects.