EMoG: Emotion-Modulated Gait Generation for Expressive Humanoid Locomotion
arXiv preprint arXiv:2609.14432 · 2026
Abstract
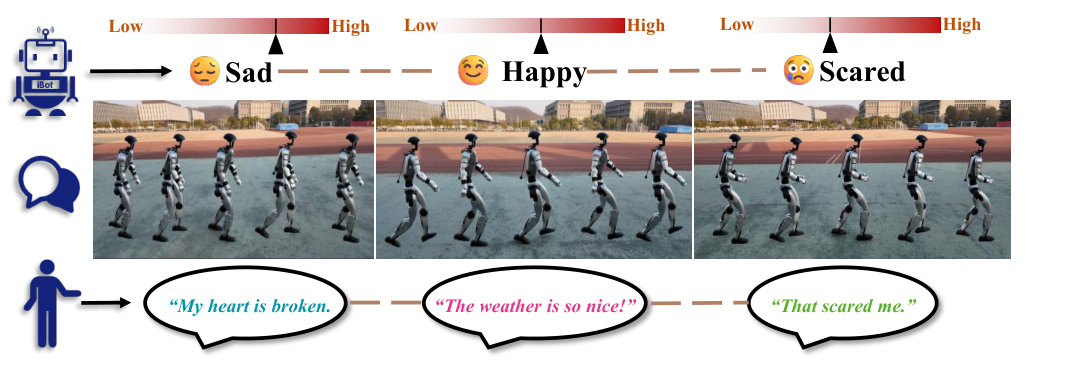
EMoG generates expressive humanoid gait trajectories with adjustable emotional style and intensity, combining physical motion commands with reinforcement-learning-based execution.